How it works
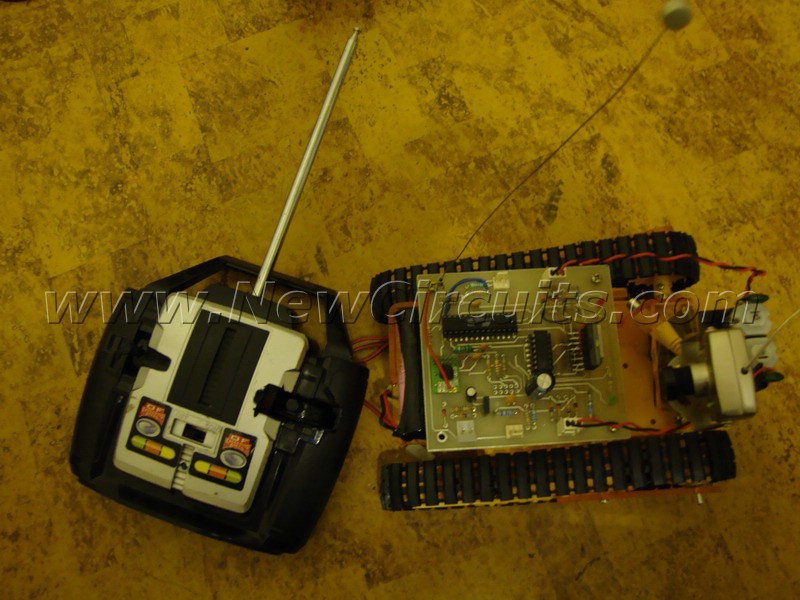
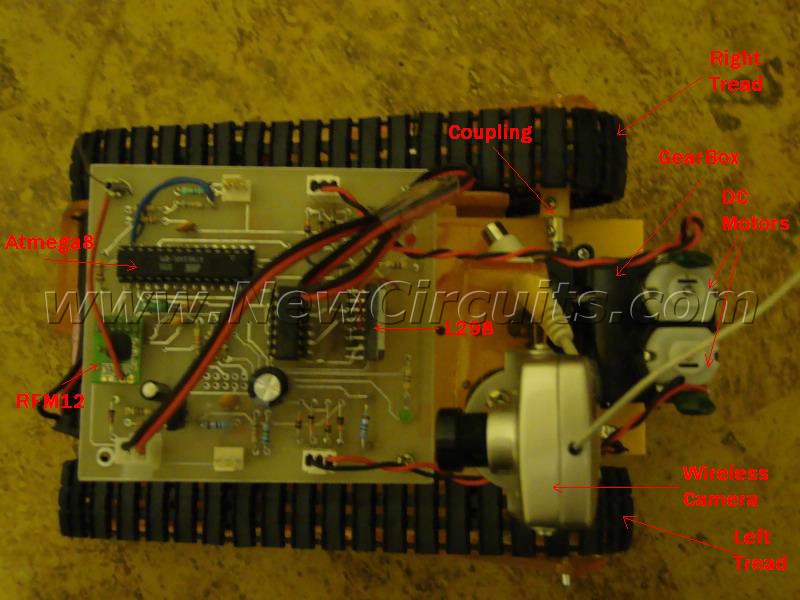
The robot reuses a tracked toy chassis with two geared DC motors. An ATmega8 generates PWM motor commands, and an L298 dual bridge controls direction. A separate RFM12 link carries steering and forward/reverse commands from the handheld controller.
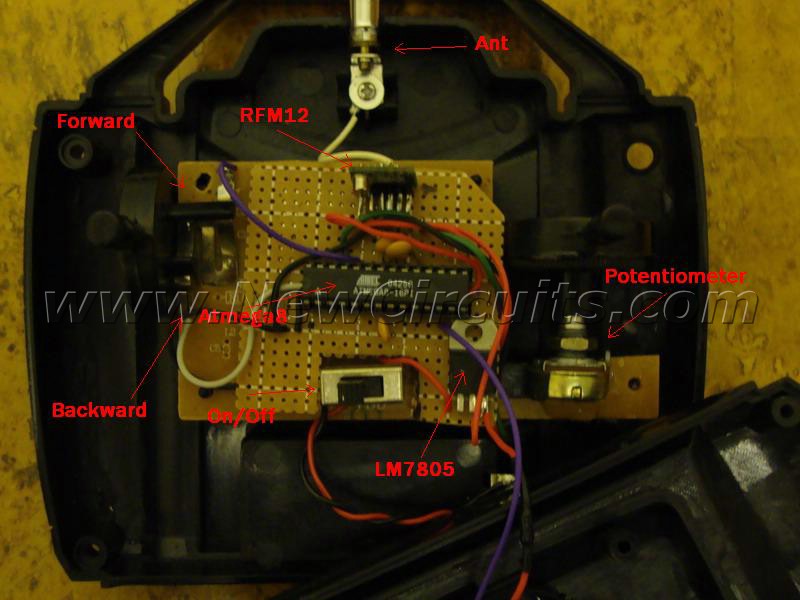
The transmitter uses another ATmega8 to read a steering potentiometer and the direction switches. The original robot also carries a separate wireless camera. Its battery is described as a 14.8 V lithium-ion pack; the old capacity notation is ambiguous and has not been silently converted to a new specification.
Original archive figures
CLICK TO ENLARGEOn the bench
Include a protected battery, appropriate fuse, and a reliable motor-stop response when communication is lost. Check radio-module voltage requirements separately from the motor supply.
Resources & provenance
Rewritten from the original projects/new/al83nb47_prjnew002.php page. Component values and historical performance claims have not been independently bench-tested.
Browse all surviving downloads →